SIMULATION / COMMUNITY CASE
jev-drone
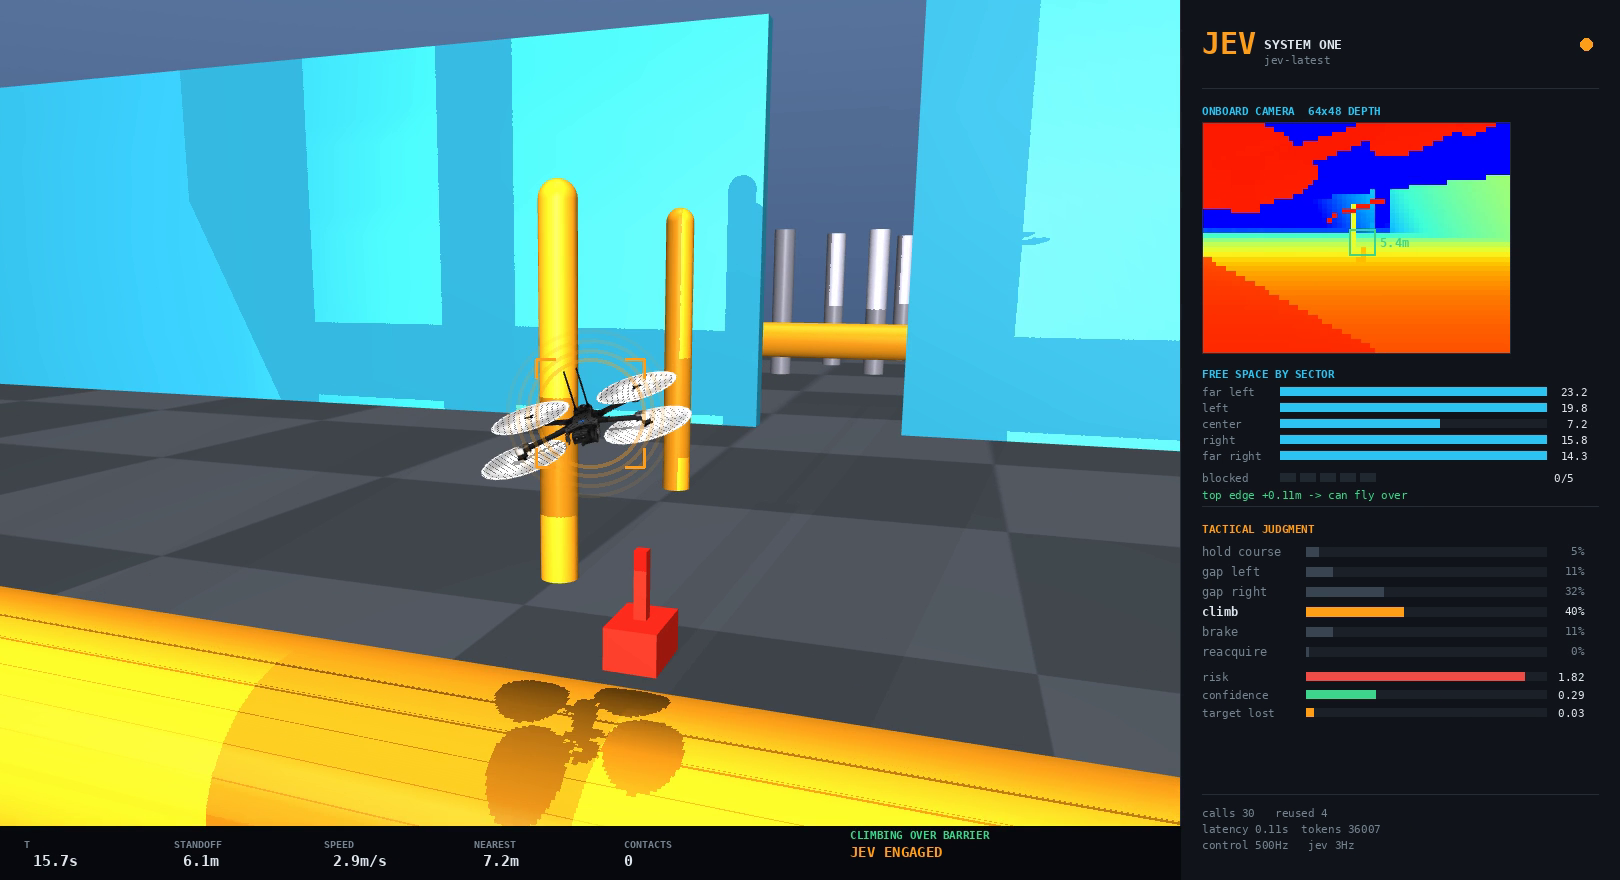
A MuJoCo drone simulation where Jev makes higher-level tactical judgments while deterministic flight control and safety limits keep authority.
Flight control is a continuous-control problem with hard safety limits, and it is not a good fit for a language-model loop.
jev-drone runs in MuJoCo simulation. Jev makes the higher-level tactical judgments, while deterministic flight control and the safety layer retain authority over what the aircraft actually does.
Jev supplies the tactical decision — what the drone should be doing — and the deterministic controller and safety limits decide how, and whether, it is executed.
RELATED CASESINSIDE JEVCASES
Case notes by JevCases. Repository snapshot dated ; claims not independently reproduced.
This is a MuJoCo simulation. The project does not present it as verified physical flight.
← RETURN TO THE CASE INDEX